Hutter’s work combines robot design, control and machine learning to create autonomous robots for challenging environments, with particular interests in legged locomotion, manipulation and navigation. He is a co-founder of ANYbotics and has long emphasized turning robotics research into practical applications, including industrial inspection and search and rescue.
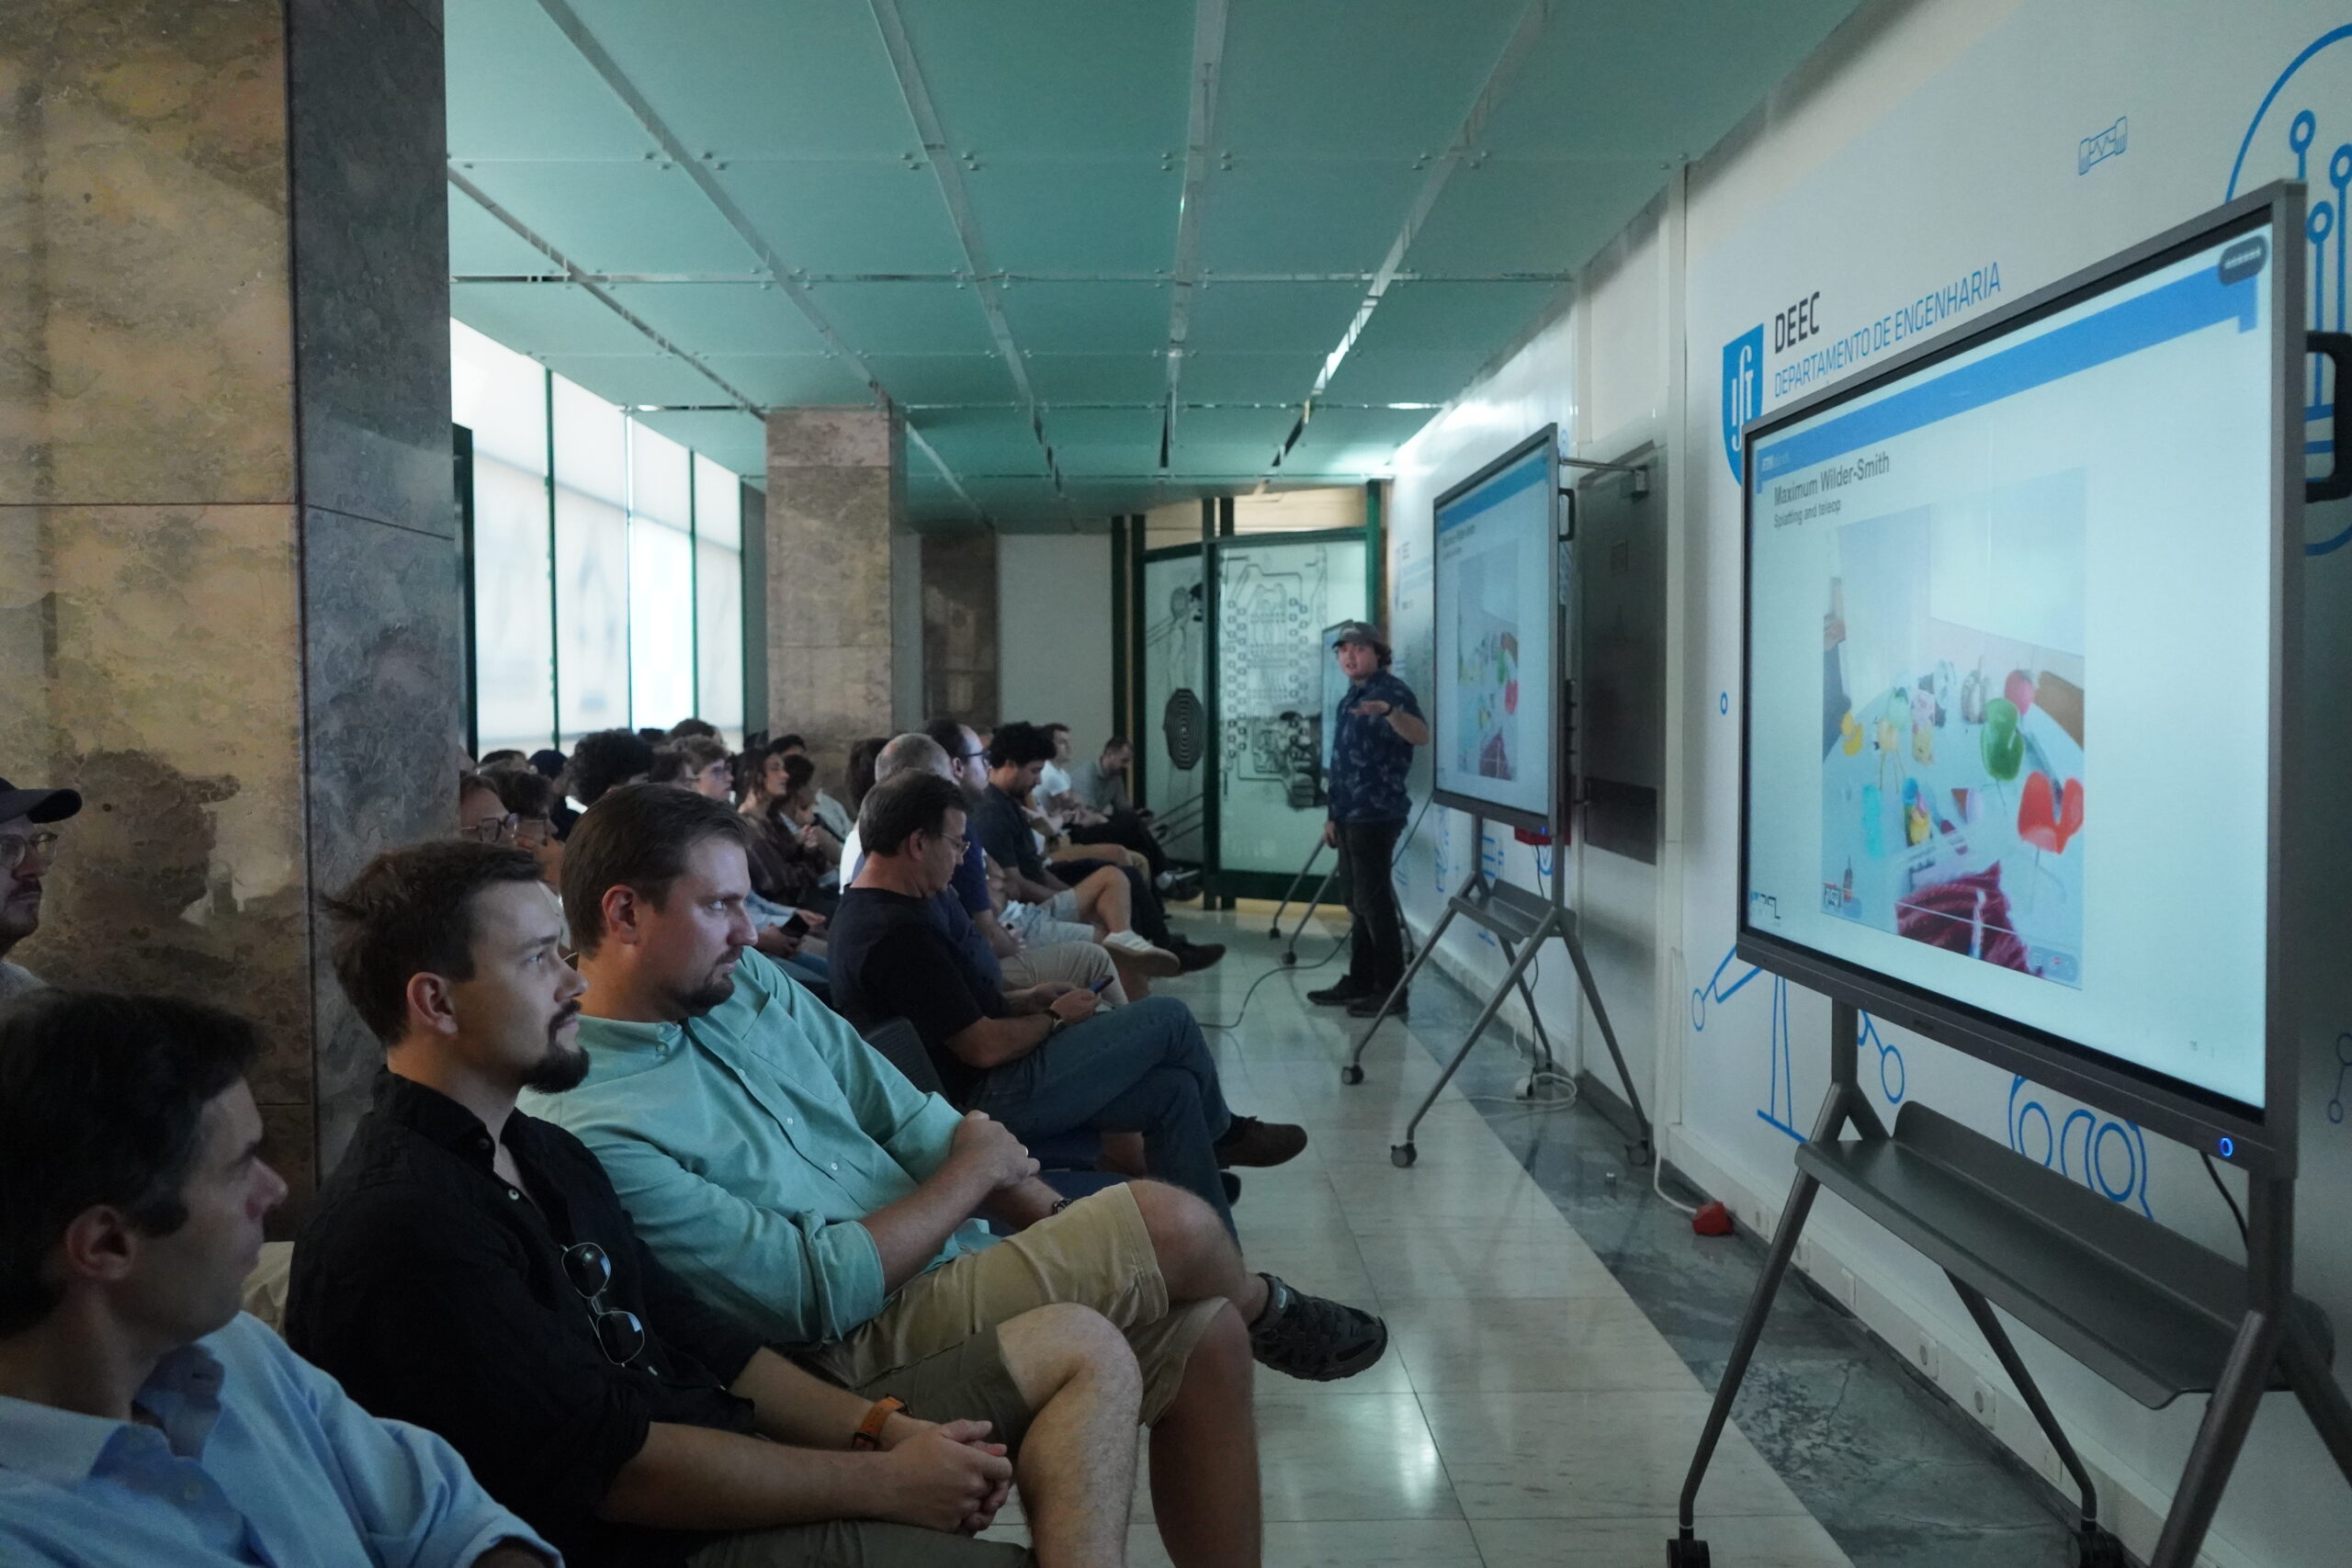
The talk, entitled “From Robot Design to Autonomy: Research at ETH Zurich’s Robotic Systems Lab” opened with a general introduction by Hutter to the lab’s research approach. Lab members then gave short presentations on selected projects spanning robot design, control, learning, perception and autonomy, with a focus on legged and mobile robotics.
Before lunch there was even time for a great group discussion on the future of automation.